Defence — Operations

Visual intelligence

in the operation.

The feed is already in the fight: night, haze, distance, a link under attack. Reseen recovers the frame and reads it before a person has to decide.

HOW IT IS USED

Three places the picture has to hold.

The same model, sat where the operation already is. Nothing is ripped out. The stream you have is the stream we read.

Air

From the airframe

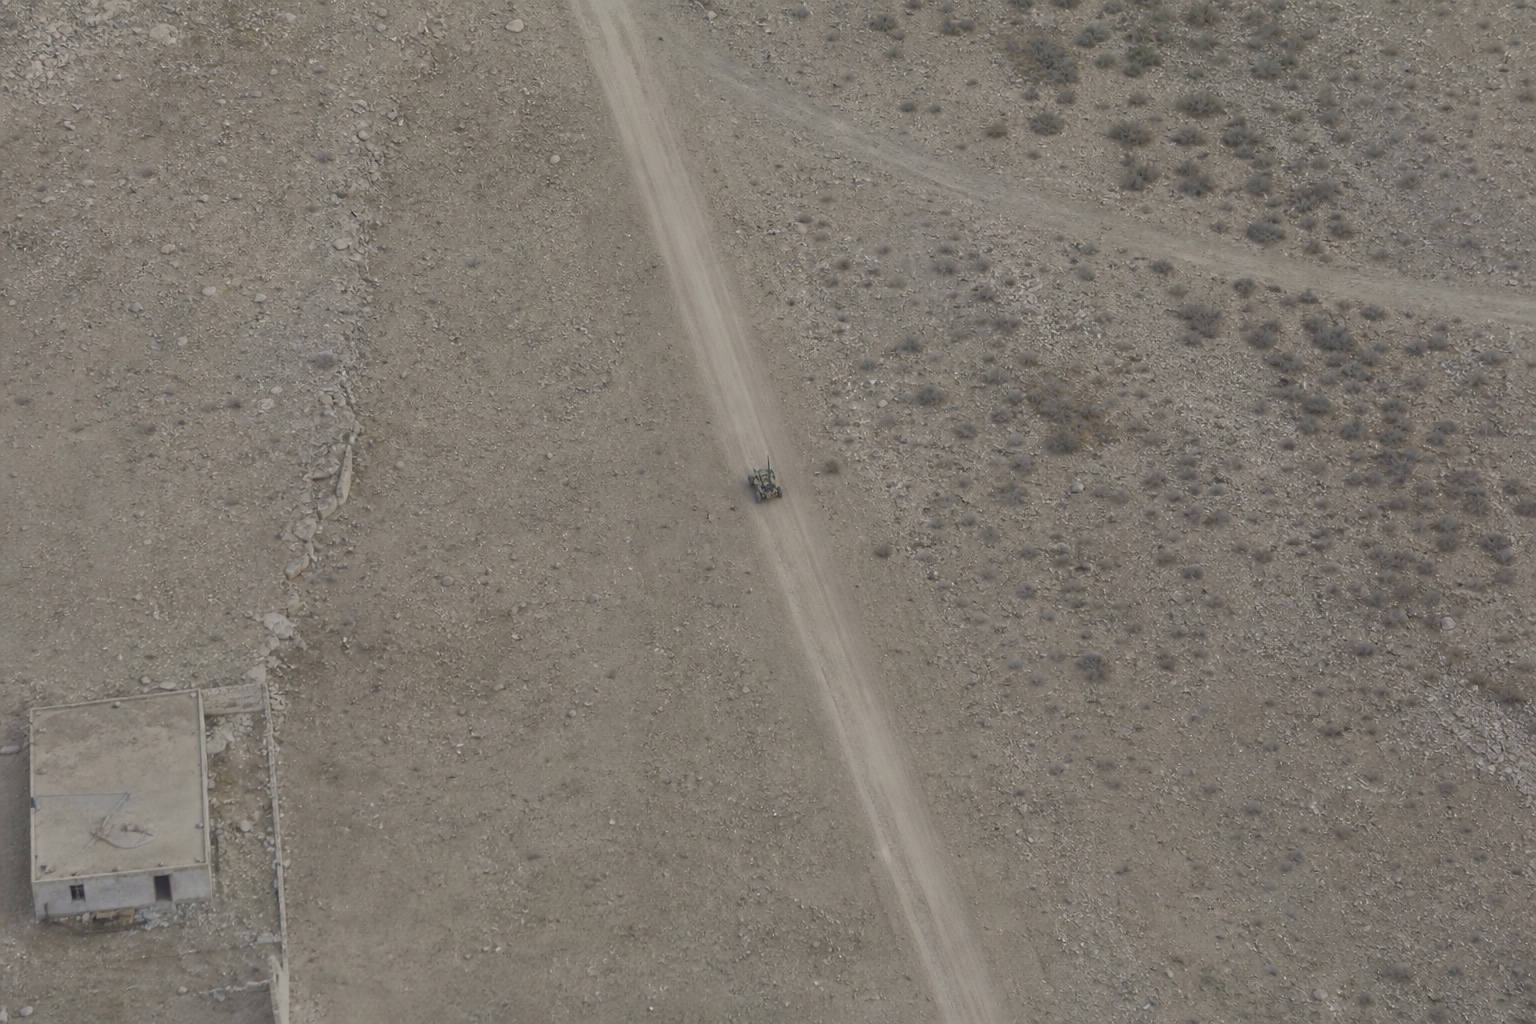
EO/IR leaves a fixed-wing or rotary platform already degraded: night, haze, stand-off, a downlink losing packets. Restoration runs before the frame reaches the ground station, so the operator and everything downstream see the recovered picture.
Ground

On the robot

On a UGV or quadruped the link is the first thing to fail. The model can sit on the platform itself: recover the frame, read it, and keep producing insights with no connectivity at all.

Fixed

On the site

Perimeter, mast and site cameras stay where they are. One integration on the streams already running. The fence keeps its cameras, its network and its data.

01 / CONTESTED TRANSMISSION

The channel is attacked.
We deliver anyway.

Every frame is encoded, encrypted, attacked in flight and arrives broken. Restoration happens after the damage, not before it — which is why the loss on the rail is real and the output still holds.

Packets sent—
Lost in channel—
Frames recovered—
Glass-to-decision< 200 ms
02 / LATENCY

Fifteen insights
between two blinks.

An operator blinks about once every three seconds and loses roughly 300 milliseconds of the world each time. We return five insights a second, so one and a half of them land inside the gap where nobody was watching.

Human blink rate0.33 / s
Blind per blink300 ms
Reseen output5 / s
Insights this session0
03 / DEPLOYMENT
Architecture

Any stream.
Any source. Anywhere.

One integration on the feeds you already run, or the whole model on the platform itself with no link at all. Nothing leaves your infrastructure.

Platform UAS

Fixed-wing and rotary, EO/IR payloads.

Platform UGV & quadruped

Ground robots under degraded comms.

Platform Fixed sensors

Perimeter, mast and site cameras.

Transport Any stream

One integration on the feeds you already have.

RTSPWEBRTCSDK
Edge On-robot

Runs on-platform. Zero connectivity required.

SDKOFFLINE
Reseen Enhance & analyse

Recover the frame, then read it. One model pass, on your hardware.

< 20 MS1080P24 FPSON-PREM
Live analysis
Operator / C2
Live alerts
Ask and search
04 / REAL-TIME VIDEO RESTORATION ONE PASS · UNDER 20 MS

Bad signal, Bad decisions.
We fix it.

We convert low-quality data into high-quality data, so the decision you take is a high-quality one.

Raw sensor against Reseen Move across the frame · or let it sweep
Raw sensor frame
The same frame after Reseen restoration
Raw sensor Reseen
Runs on1 GPU · on-prem
Analysis with Vision-Language Models Ask the frame · answer in one model pass
Aerial reconnaissance frame under vision-language analysis Live EO · nadir · 2.4 km UGV · 0.97 STRUCTURE
Ask about this live frame

Reseen 1.7
Reseen · one pass · 180 ms

Reseen Systems

Bring the feed
that fails.

The one from the operation nobody can use. We will show you what is still in it.

AI to protect Democracies